 English
 Español
 Português
 Deutsch
 한국어
 日本語
 Italiano
 Français
 العربية
 Türkçe
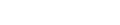
MScape N210 Edge AI Computer for Robot Sensor Fusion
- Third-Generation Robot Brain
- 14-Sensor Fusion + EtherCAT
- Xenomai Real-Time Core

Compact Multi-Protocol Intelligence for Robot Builders

Compact robot-side deployment
Multi-protocol device communication
Sensor fusion and real-time interconnect
When to Choose N210
Sensor Fusion Is Central
Industrial Interconnect Matters
Space and Reliability Matter
N210 Engineering Highlights
14-Sensor Fusion Path
N210 supports a sensor-rich robot architecture with 14-sensor fusion, helping humanoid, service, and mobile robot teams connect perception and control signals inside a compact platform.
EtherCAT High-Speed Interconnect
The platform supports 4-way EtherCAT high-speed interconnect, making it suitable for robots that need deterministic communication between controller, sensors, and motion systems.
System Protection and Power Management
N210 includes independent USB power management, high-speed Wi-Fi, and system protection features for more reliable robot-side deployment.
N210 Specification Summary
Use this table as a first evaluation layer. Confirm exact values and interface definitions in the official N210 technical manual.
| Product Role | Compact robotics edge AI computer for embodied intelligence |
|---|---|
| Robot Platform | Third-generation humanoid robot brain platform |
| Sensor Path | 14-sensor fusion architecture |
| EtherCAT | 4-way EtherCAT high-speed interconnect |
| Power Management | Vehicle-grade connector design with independent USB power management |
| Real-Time Support | Commercial-grade EtherCAT bus plus Xenomai hard real-time core |
| Best Fit | Compact robots needing sensor fusion, industrial interconnect, and reliable robot-side deployment |
Related Technical Guides
Orin NX vs AGX Orin for Robot Computers: Whole-System Trade-offs
Translate an Orin NX versus AGX Orin module choice into a robot-computer shortlist using memory, cameras, interfaces, power and installed validation.
Learn More
Robot Computer Power and Restart Validation on a Shared DC Bus
What to measure during boot, load changes and power interruption when a Jetson-based computer shares a robot DC bus.
Learn More
Robot Computer Thermal Validation in an Installed Build
A practical test and evidence record for validating a Jetson-based robot computer in its actual enclosure, workload and service condition.
Learn More